Senior ML & robotics research engineer. Building learning-based systems for autonomous driving and embodied AI.
A selection of public systems and engineering efforts I have contributed to. For the corresponding papers, see the research page.
Autonomous Driving Systems
Data, perception, and learned behavior systems for long-range highway autonomy.
TruckDrive dataset Built synchronized long-range LiDAR, radar, camera, dense depth, refined ego-pose, and 2D/3D label pipelines for 475k highway scenes. Project Paper
Lane-line pseudolabeling Developed a lane-line model integrated into a new end-to-end production pipeline, with data-quality analysis spanning human annotation and online depth estimation.
Learned behavior modeling Mitigated trajectory-prediction mode collapse through loss design and curriculum fine-tuning; improved evaluation, experiment comparability, parallel training, and hyperparameter optimization.
Embodied AI & Tactile Robotics
Robust learning systems for real-world robotic manipulation.
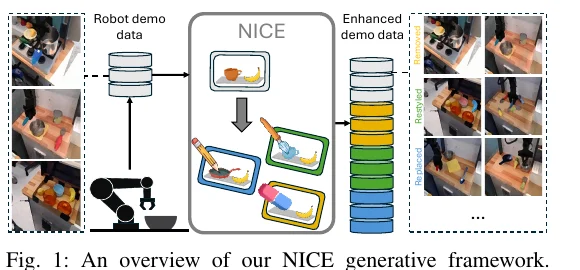
NICE scene surgery Built a scalable augmentation toolkit that analyzes real robot scenes and uses generative models plus LLM suggestions to recolor, retexture, remove, inpaint, and replace distractor objects while preserving action labels. Paper
Grounded language agents and reproducible simulation infrastructure.
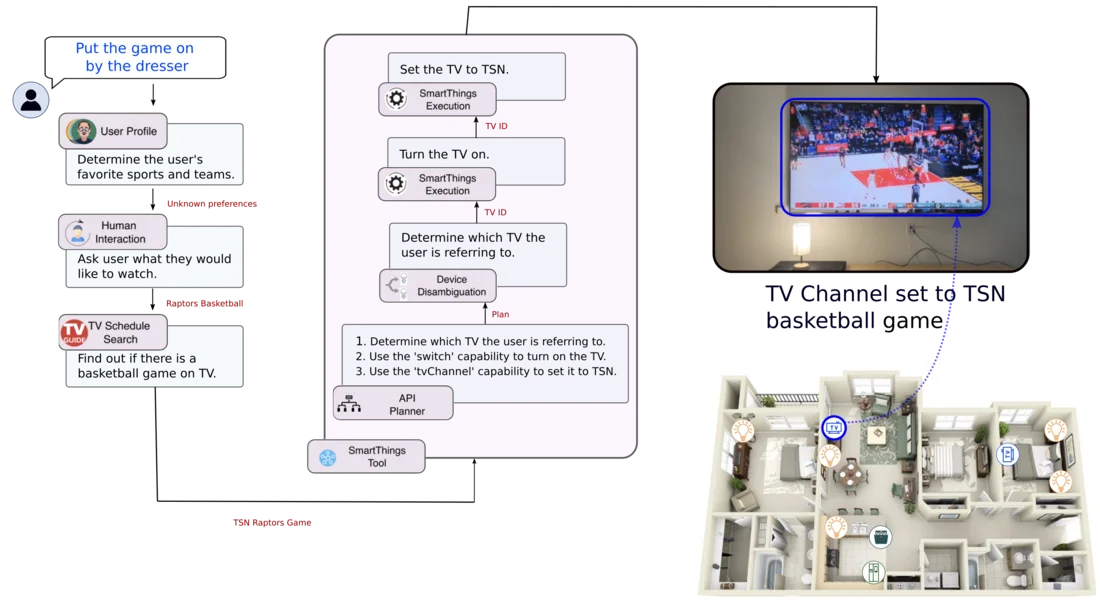
SAGE smart-home agent Integrated LLM planning, retrieval from interaction history, smart-device and web APIs, visual-language models, and generated code. Led external API and smart-TV interaction plus multimodal evaluation. Project Paper
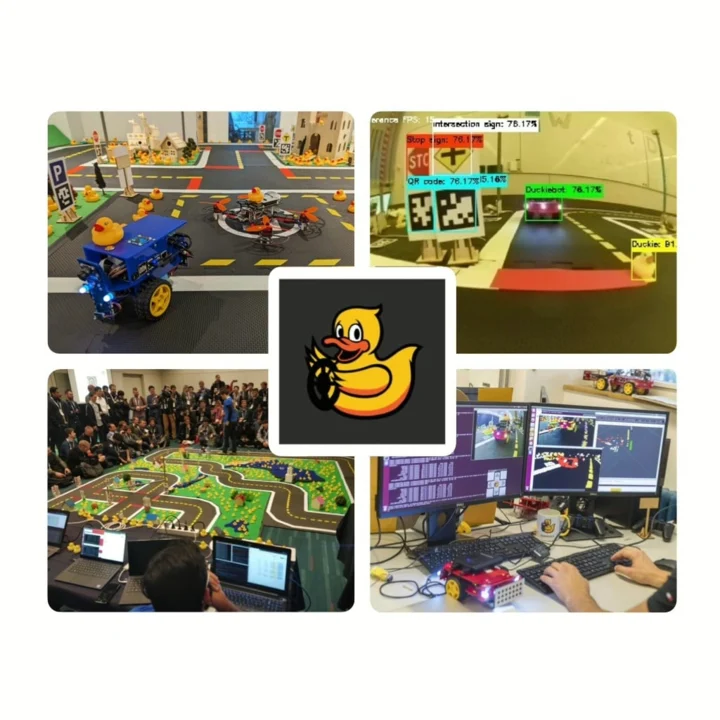
Duckietown learning autonomy Developed generative domain-randomization methods for imitation learning, reinforcement learning, and computer vision in the Duckietown autonomous-vehicle simulator. Project Code